2021/Final year thesis, Monash University
A walking robot with one leg missing, at a quarter of the price.
25% cheaper than comparable quadrupeds
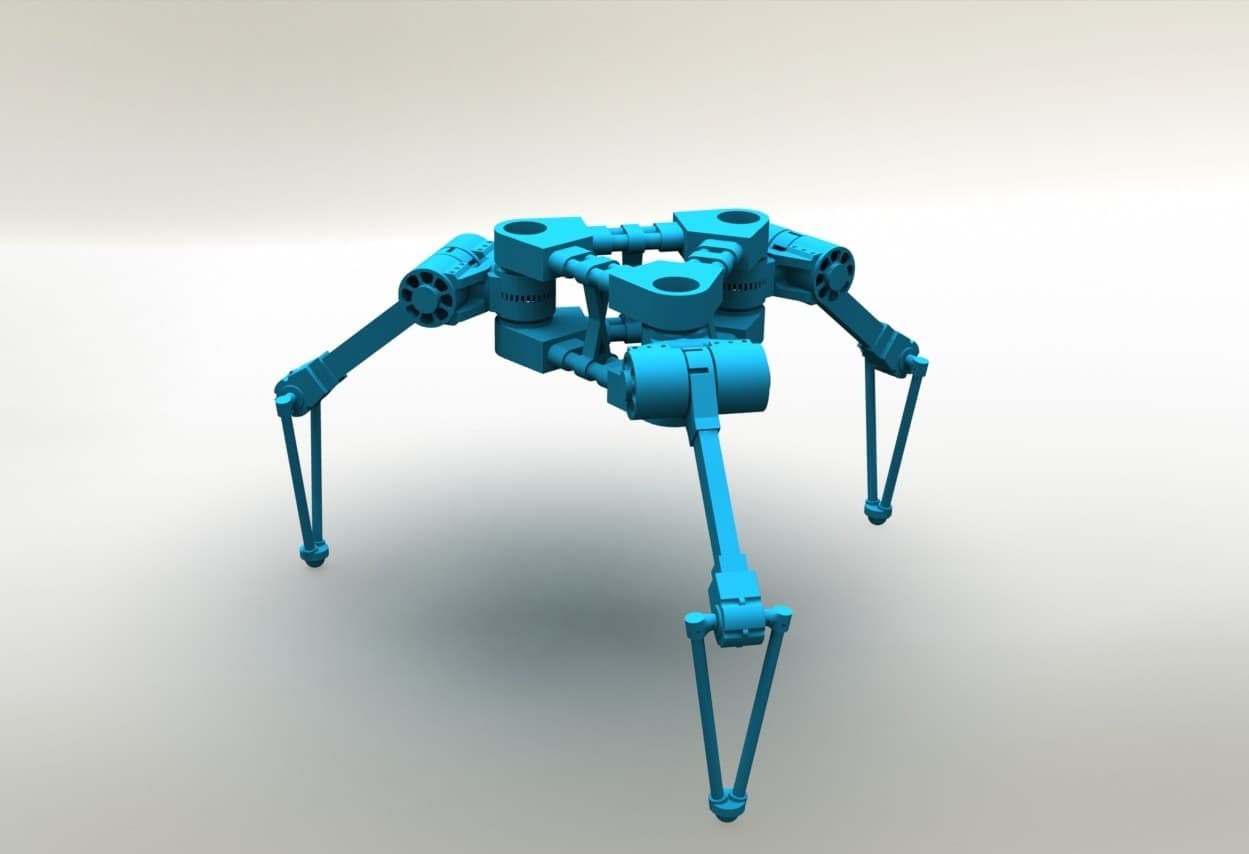
Four legs is the accepted minimum for a walking robot, and four legs is expensive. My final year thesis took one off and let the robot work the rest out for itself. It taught itself a gait with nothing hand-coded, printed on a desktop machine.
How it works
Legged robotics takes it as read that you need four legs for stable walking. I wanted to know how much of that was physics and how much was convention, so I removed one and trained a reinforcement learning controller from scratch to cope. There is no motion planner in it and no gait I designed. The robot works out how to compensate for its own asymmetry through trial and error, and what emerges is a functional, slightly odd-looking walk. It is fully 3D printed, runs on a Raspberry Pi, and uses a custom ROS control stack. The bill of materials came in at a quarter of a comparable quadruped.
Built with
Got something in this shape?
Tell me what it needs to do and who has to live with it afterwards.